AMR
EN · Autonomous Mobile Robot
Robot that can navigate and plan missions in its environment, within system limitations.
ROBOTICS TERMINOLOGY
Search robotics acronyms and technical terms: English definitions, practical explanations and topic filters.
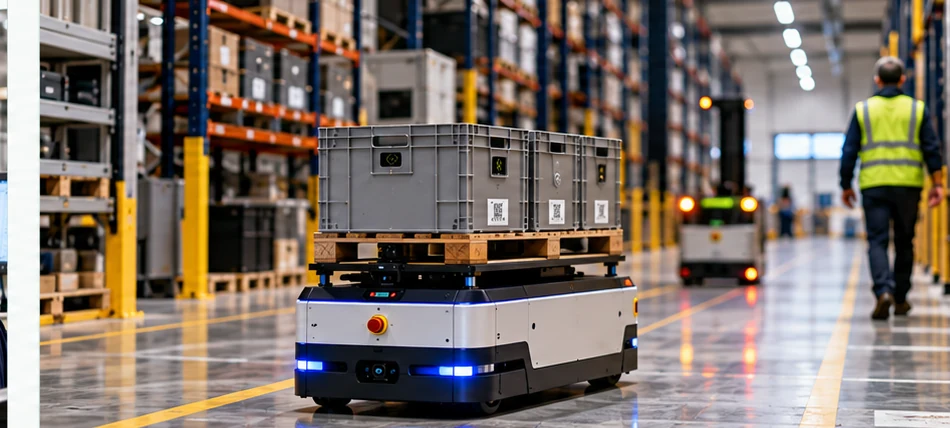
EN · Autonomous Mobile Robot
Robot that can navigate and plan missions in its environment, within system limitations.
EN · Automated Guided Vehicle
Industrial vehicle guided along defined or configured routes.
EN · Return on Investment
Economic indicator relating a benefit or return to the capital invested.
EN · Key Performance Indicator
Measure used to verify achievement of an objective.
EN · End-of-Arm Tooling
Gripper, suction cup, tool or other device attached to the robot wrist.
EN · Simultaneous Localization and Mapping
Technique for estimating position and building or updating a map.
EN · Light Detection and Ranging
Distance sensor based on the emission and reception of laser light.
EN · Computer Numerical Control
Programmed control of machine tools.
EN · Selective Compliance Assembly Robot Arm
Manipulator architecture commonly used for assembly operations.
EN · Application Programming Interface
Rules and functions enabling different software systems to communicate.
EN · Portable Document Format
Digital document format.
EN · International Organization for Standardization
International organisation that publishes technical standards.
EN · International Electrotechnical Commission
Electrotechnical standardisation body.
EN · Italian National Standards Body
Italy's national standardisation body; UNI is not an English acronym.
EN · European Norm
Abbreviation used for European standards; not to be confused with EN as a language code.
EN · European conformity marking
Regulated marking indicating conformity with applicable requirements; it is not a quality mark.
EN · European Union
Supranational organisation, abbreviated EU in English.
EN · Technical Specification
A type of technical standards document.
EN · Artificial Intelligence (AI)
Technologies that perform tasks associated with artificial intelligence.
EN · Artificial Intelligence
English acronym for artificial intelligence.
EN · Request for Information
Preliminary document addressed to suppliers.
EN · Request for Quotation
Structured request for a commercial quotation.
EN · Enterprise Resource Planning
Software for business processes and data.
EN · General Data Protection Regulation
EU Regulation 2016/679 on the protection of personal data.
EN · Ingress Protection (in the context of enclosure ratings)
Classification of protection against dust and water; IP can have other meanings in computing.
EN · Secure Sockets Layer
Term still used colloquially for HTTPS; the modern protocol is TLS.
EN · PHP: Hypertext Preprocessor
Server-side scripting language.
EN · HyperText Markup Language
Structural language for web pages.
EN · Cascading Style Sheets
Language for styling web pages.
EN · Robot Operating System
A collection of libraries and tools for robotics applications.
EN · Near Field Communication
Short-range wireless communication technology.
EN · Quick Response
A type of two-dimensional code.
EN · Industrial robot
Programmable manipulator used for industrial automation tasks.
EN · Robotic arm
Articulated or kinematic system that positions a tool or object in space.
EN · Collaborative robot
Robot suitable for collaborative applications designed with specific safety measures.
EN · Collaborative robot (cobot)
Common term for a robot designed for collaborative applications; safety depends on the complete application.
EN · Mobile manipulator
System combining a mobile base with a manipulation device.
EN · End effector
Device mounted at the end of a manipulator, such as a gripper or tool.
EN · Robotic gripper
Device that grasps and holds parts during operations.
EN · Vacuum gripping
Gripping technique using suction cups and a pressure difference.
EN · Payload
Permissible mass handled by the robot under stated conditions; includes tooling and the workpiece where relevant.
EN · Reach
Extent reachable by a manipulator, to be verified along the actual trajectory.
EN · Repeatability
Ability to repeat a position or performance under specified test conditions.
EN · Accuracy
Closeness of an obtained value to a reference value; distinct from repeatability.
EN · Cycle time
Time required to complete a defined operating sequence.
EN · Availability
Proportion of time during which the system is available to perform its intended service.
EN · Productivity
Ratio of outcomes achieved to resources used in a process.
EN · Payback period
Time required to recover the investment through the economic flows considered.
EN · Total cost of ownership
All lifecycle costs: purchase, integration, operation and maintenance.
EN · Feasibility study
Preliminary analysis of a project's requirements, constraints, risks, benefits and costs.
EN · Pilot test
Controlled trial in an operating scenario to verify assumptions and performance.
EN · Functional requirement
Function or behaviour that the system must provide.
EN · Technical specifications
Documented description of required characteristics, performance and constraints.
EN · System integration
Connection and coordination of components, software, machines and infrastructure.
EN · Autonomous navigation
A mobile system's ability to reach destinations using localisation, planning and control.
EN · Localization
Estimation of robot position relative to a map or reference.
EN · Mapping
Creation or updating of a representation of the environment.
EN · Path planning
Search for a route compatible with geometric and operating constraints.
EN · Path replanning
Calculation of an alternative route when conditions or constraints change.
EN · Obstacle avoidance
Strategies for detecting and responding to obstacles; may include stopping and detouring.
EN · Fleet management
Coordination of missions, priorities and traffic for multiple mobile robots.
EN · Inertial navigation
Motion estimation using inertial sensors, often integrated with other systems.
EN · Machine vision
Image capture and processing for detection, measurement or guidance.
EN · Safety sensor
Device used in a designed and verified protective function.
EN · Emergency stop
Stop function that can be activated in a hazardous situation; it does not replace other protective measures.
EN · Protective stop
Stop triggered by a protective function according to the system's safety logic.
EN · Risk assessment
Process of identifying hazards and assessing risks, including the definition of risk-reduction measures.
EN · Residual risk
Risk remaining after risk-reduction measures are applied.
EN · Interlocking guard
Physical guard associated with a function that monitors access and operating conditions.
EN · Safety distance
Separation required to restrict access to a hazard under the design conditions.
EN · CE marking
Regulated marking relating to conformity with the EU requirements applicable to the product.
EN · Preventive maintenance
Scheduled activities to reduce the likelihood of failures or performance degradation.
EN · Commissioning
Configuration, verification and commissioning of a system in its operating environment.
EN · Validation
Documented confirmation that a system meets the requirements for its intended use.
EN · Acceptance testing
Agreed verification of performance and requirements before acceptance.
EN · Human-machine interface
System through which operators view information and issue commands.
EN · Digital twin
Digital representation linked to a real asset or process, according to its purpose and degree of integration.
EN · Simulation
Model of a system's behaviour used for analysis or virtual experimentation.
EN · Remote control
Control or supervision of a system from a remote location.
EN · Telemetry
Collection and transmission of data on system status or performance.
EN · Interoperability
Ability of different systems to exchange and use information in a coordinated way.
EN · Cybersecurity
Protection of systems and data from unauthorised access, alteration and disruption.
EN · Robot controller
Hardware and software unit managing robot movement and functions.
Try a broader term or select “All entries”.