01 / FIXED ROUTE
AGV conventional
Ready. Start the comparison.
EXPERIENCE LAB
Compare the illustrative behaviour of AGV and AMR in the presence of obstacles. This demonstration does not validate navigation or safety.
ROBOT EXPERIENCE LAB
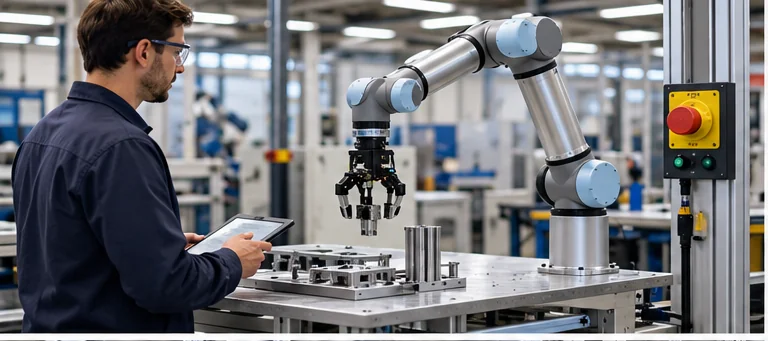
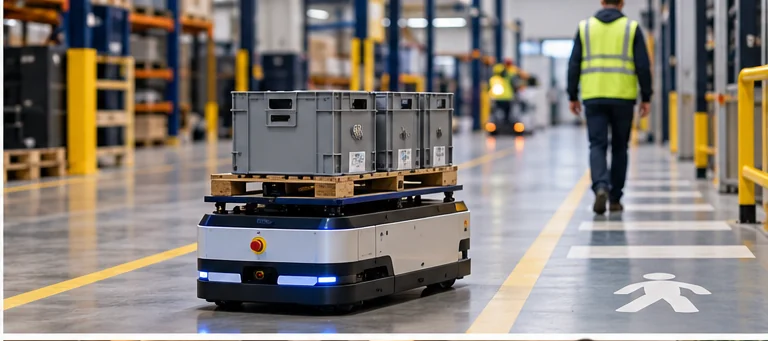
Compare AGV and AMR in a 2D demo and follow a dish-transport mission. Enter site measurements and technical data from identifiable documents, without assuming universal performance for mobile robots. The animated mission remains illustrative.
INTERACTIVE DEMO · NAVIGATION COMPARISON
Compare an AGV following a fixed route with an AMR with route replanning. Click the floor-plan cells to add or remove obstacles. The AMR model calculates a new route on the grid when one exists.
Ready. Start the comparison.
Ready. Start the comparison.
Educational model, not a safety simulation. TheAGV shown follows a fixed route without detour capability; other AGV may have different functions. TheAMR uses an A* search on an abstract grid, not sensors, SLAM or real motion control. The robot stops when it cannot find a clear route. No displayed time, distance or safety margin represents commercial performance.
Staff load the dishes, the robot transports them to the wash area and an operator unloads them. Explore the stages and see how an AMR with dynamic navigation can choose an alternative route when one is available.
Speed, dimensions and payload vary between machines. Enter values from identifiable technical documentation; the site does not verify them automatically or use preset parameters.
Explore the method and literature ↗Qualitative animation, not a physics simulation: the alternative route is drawn in advance and does not result from a real planning algorithm, sensors or risk assessment. An AMR may stop if no safe passage exists. Animation time does not correspond to travel time. Results require completed inputs; speed and technical limits also require a stated source. Loading and unloading remain manual operations.
Theoretical time = entered distance / technical speed supplied by the visitor with a document reference. Excludes acceleration, turns, traffic, stops, loading/unloading and charging: it is not a forecast of actual times.
Technology alone is not enough. Routes, people, safety, operations and maintenance determine actual feasibility.
Describe the process, spaces and constraints. The initial discussion is exploratory; any analyses and site visits are agreed separately.